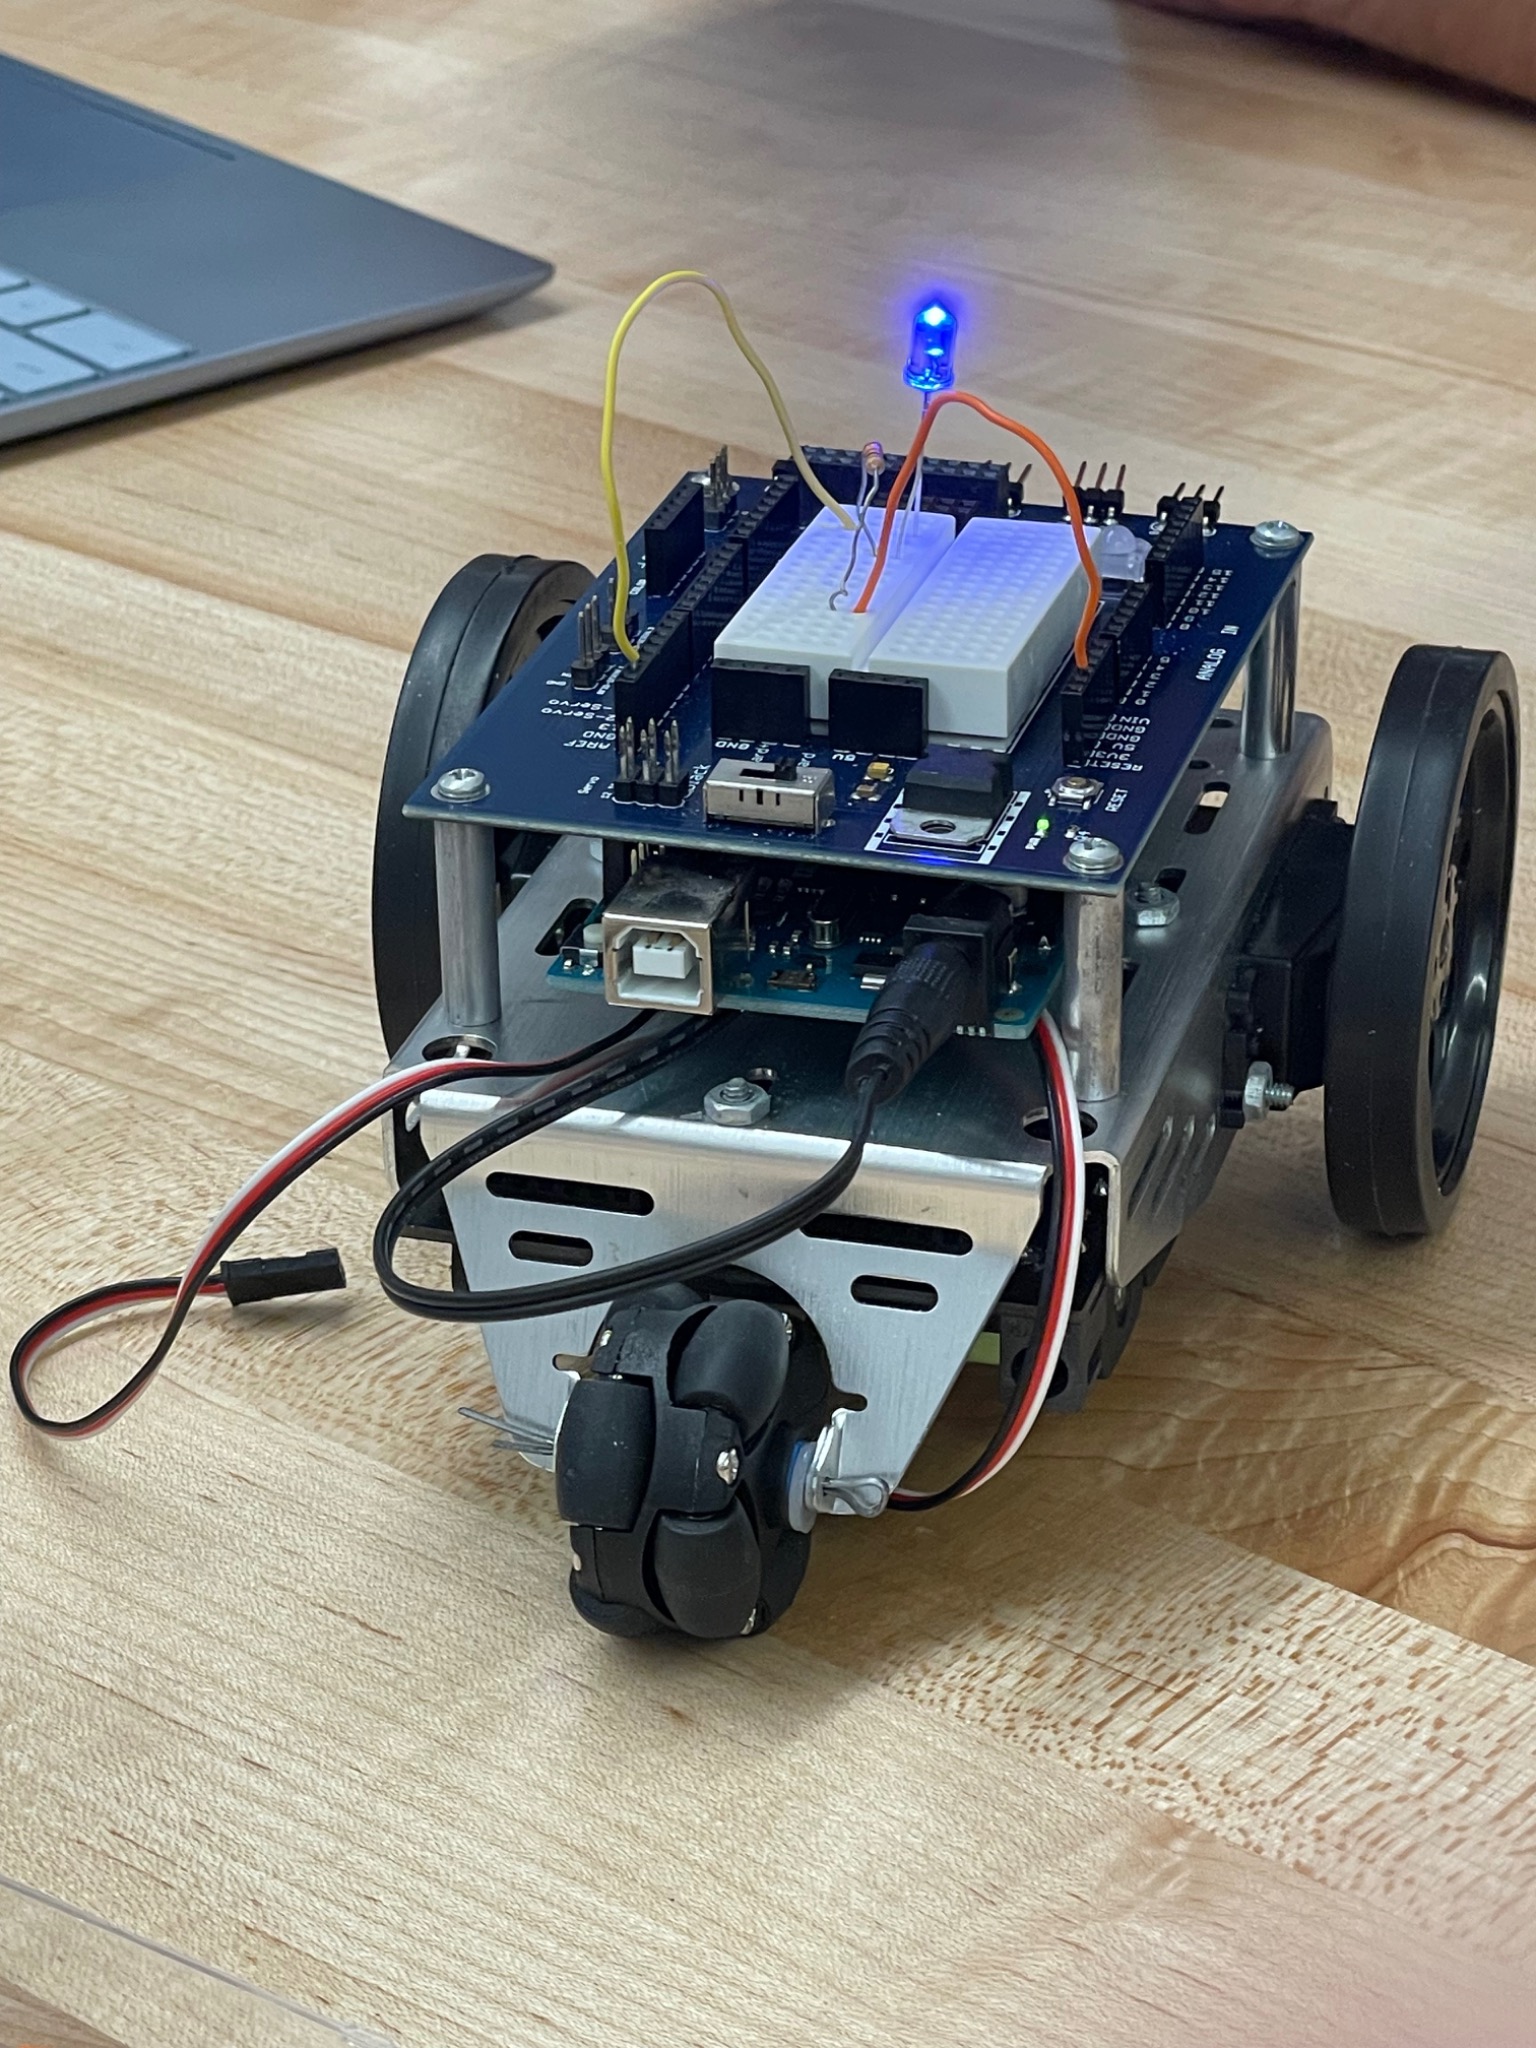
Arduino Sensing & Communication Robot
Connecting controlled motion, line following, target sensing, and wireless reporting
The Project
I helped build and program an Arduino-based robot that navigated a marked course, sensed a target on the map, and relayed information about what it found. The project connected physical construction, embedded programming, sensor feedback, and communication between robots.
Robot construction
Arduino programming
Sensing and reporting
Duke ECE 110L
Integrated Design Challenge
Spring 2025
Servo control · QTI sensing
Serial communication · XBee
Hardware/software integration
Technical Overview
- Controller Platform
- Arduino / ATmega2560 platform used in the course
- Motion
- Two-wheel drive using continuous-rotation servomotors
- Route Feedback
- QTI infrared reflectance sensors for line following and track markers
- Wireless Reporting
- XBee module communicating through an Arduino hardware serial port
From Motion to an Integrated System
Controlled Motion and Line Following
The robot used continuous-rotation servomotors to drive its wheels. QTI sensors provided feedback from the track, allowing the navigation code to respond to the line and recognize marked sensing locations.
Target Sensing
The challenge assigned each robot a sensing task at marked locations on a map. The program needed to determine whether the assigned target was present and report its location, rather than simply reacting to any object.
Serial and Wireless Communication
The lab used XBee modules to exchange information between robots. The Arduino communication code sent encoded findings through a hardware serial port, connecting the robot’s sensing result to the larger team system.
System Feedback and Data Handling
The full challenge required RGB LEDs to show navigation, sensing, and communication states. It also called for receiving other robots’ results, displaying team data on an LCD, and calculating a follow-up action from the combined information.
My Work
I worked on the robot’s construction and wrote Arduino code for sensing and reporting findings. The technical work connected sensor inputs with programmed behavior and made the information gathered on the course available to the communication system.
Skills Applied
Arduino programming · Embedded systems · Servo control · QTI line following · Sensor integration · Serial communication · XBee wireless communication · System integration